UW RoboSoccer
Humanoid platform · ongoing
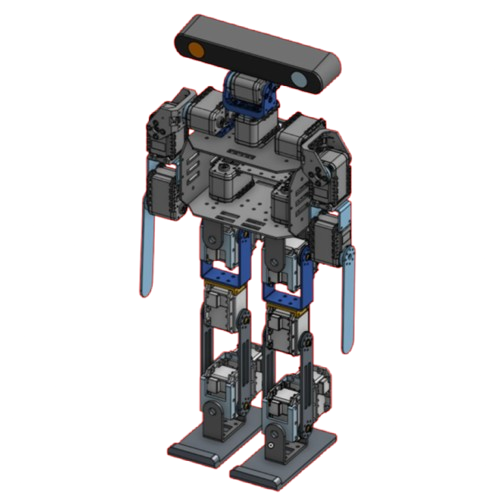
We are building four roughly 50 cm tall humanoid robots to compete in RoboCup. The goal is an affordable, accessible platform with reinforcement learning control spanning bipedal movement and game strategy.
Approach
- Design for manufacturing and low weight
- Low-cost serial bus actuators and accessible hardware
- MuJoCo simulation and specialized reinforcement learning environments
See the control environment on GitHub.