Wheel-legged robot
Mobility in unstructured environments
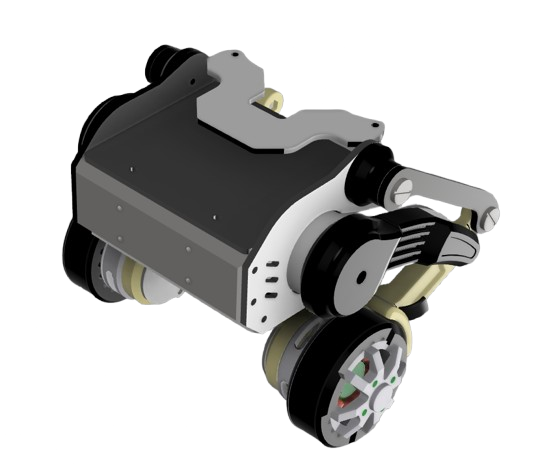
A self-balancing robot designed around stability, low mechanical complexity, and energy efficiency. Each leg is a four-bar linkage driven by one hip actuator, keeping the platform level while changing ride height.
Controls
- BLDC torque control with SimpleFOC and magnetic encoder feedback
- Pitch and position stabilization using a four-term feedback controller
- Roll-stabilized leg height, yaw control, fall detection, and recovery
- Synchronized jump trajectories using serial bus servos